
Student engineering · 2026-09-02
Self-Balancing Robot with a PID Controller: FYP Build Guide.
A deep dive into the mathematical modeling, complementary filter sensor fusion, PID loop tuning, and mechanical chassis design of an inverted pendulum robot.
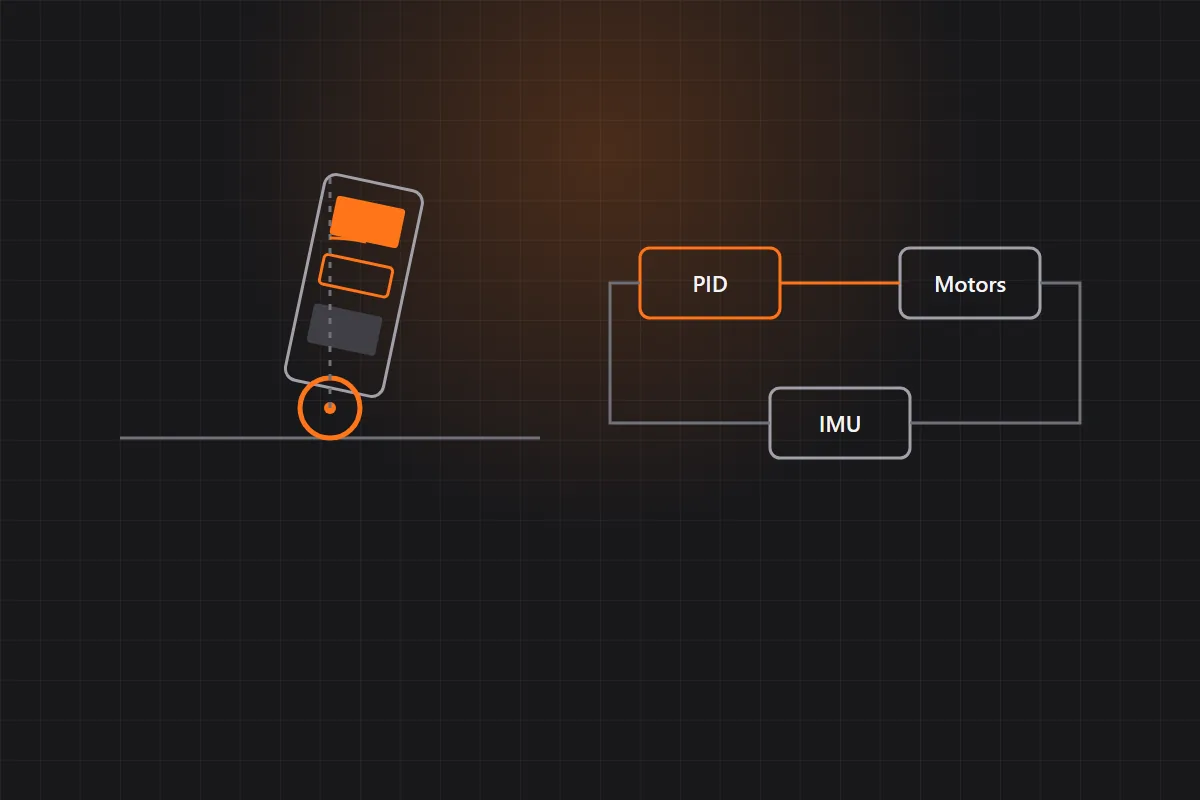
The two-wheeled self balancing robot using pid controller is a classic, universally respected capstone project for Mechatronics, Electrical, and Control Systems engineers looking for standout final year project ideas in Pakistan to build a demonstrable fyp prototype. Modeling an inverted pendulum tests a team's mastery of dynamic differential equations, digital sensor signal filtering, high-speed PWM motor control, and rigid mechanical chassis fabrication.
1. Inverted Pendulum System Architecture
The self-balancing robot maintains upright stability by driving its wheels in the direction that the upper chassis is falling. The hardware pipeline consists of four interconnected subsystems:
- IMU Angle Sensing: An MPU-6050 sensor mounted near the center of gravity measuring angular rate and gravitational acceleration vectors.
- Sensor Fusion Filter: Combining low-pass filtered accelerometer angles with integrated gyroscope angular rates using a complementary filter to obtain drift-free pitch angles.
- Microcontroller PID Processing: Executing a high-frequency (200Hz) timer interrupt loop calculating required motor compensation torque based on proportional, integral, and derivative terms.
- Motor Driver & Actuators: Dual H-bridge driver (TB6612FNG or L298N) modulating 12V geared motors equipped with quadrature encoders.
2. Practical PID Tuning Procedure
Tuning the PID controller requires a methodical, step-by-step approach:
- Set Ki = 0 and Kd = 0. Gradually increase proportional gain Kp until the robot responds to tilt and begins oscillating slowly around the vertical setpoint.
- Introduce derivative gain Kd to dampen the oscillations and eliminate overshoot. Continue increasing Kd until the robot resists sudden push disturbances without shuddering.
- Introduce a small integral gain Ki to eliminate steady-state tilt error, enabling the robot to maintain a stationary balance point without drifting forward or backward.
Frequently Asked Questions
Why does my self-balancing robot oscillate violently and fall?
Violent oscillations indicate excessive proportional gain (Kp) or insufficient derivative gain (Kd). Inverted pendulum robots also require fast loop execution rates (at least 100-200 Hz) and backlash-free gear motors with optical encoders.
What sensor should I use to calculate the tilt angle?
The MPU-6050 6-axis IMU (gyroscope + accelerometer) is standard. Combine the raw readings using a Complementary Filter or Kalman Filter to eliminate gyro drift and accelerometer vibrational noise.
Which motors are best for a self-balancing robot FYP?
High-speed metal geared DC motors with built-in Hall effect encoders (e.g. JGB37-520 12V 330RPM) or NEMA 17 stepper motors driven by A4988/TMC2209 drivers.
Need help with the next step?
Need Help Fabricating or Tuning Your Robotic FYP?
PakMEC provides complete Mechatronics FYP support including high-torque motor selection, custom laser-cut chassis, and control algorithm implementation.